DOE/LANL Jurisdiction Fire Danger Rating:
  1. LANL Home
  2. Engage with LANL
  3. Collaboration
  4. Internships
  5. Summer Schools
  6. rass

Previous RASS Projects and Publications

Learn about past RASS projects and publications

Projects are an integration of automation hardware and software

Each team of three students designs and fabricates a proof-of-concept system that solves a Laboratory problem. These multi-disciplinary projects require students to collaborate across engineering and science disciplines.
Past Projects

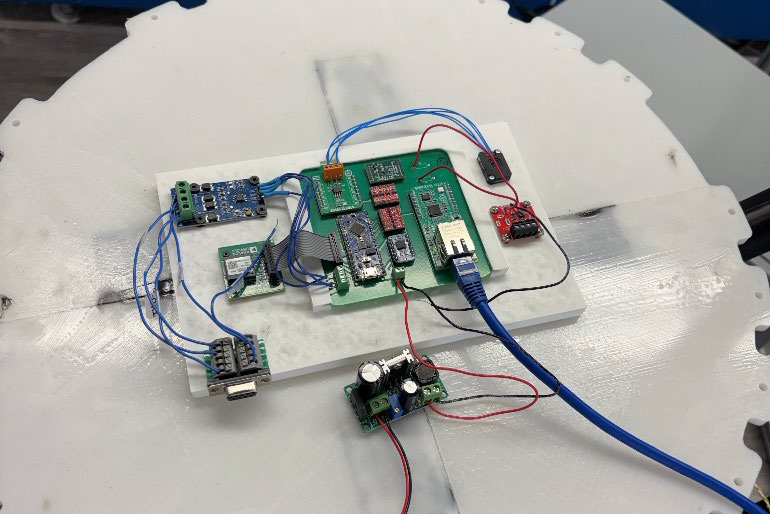
A circuit board with various connectors

This project developed a three-axis gimbal for calibrating inertial measurement units (IMUs) and other sensors through controlled positioning and rotation. The system supports calibration of sensors installed within a payload and combines programmable motion control, a custom sensor data acquisition board, and a LabVIEW interface to automate test sequences and display sensor and system data.

Sponsor and Collaborator: Engineering Technology Maturation and A-3 

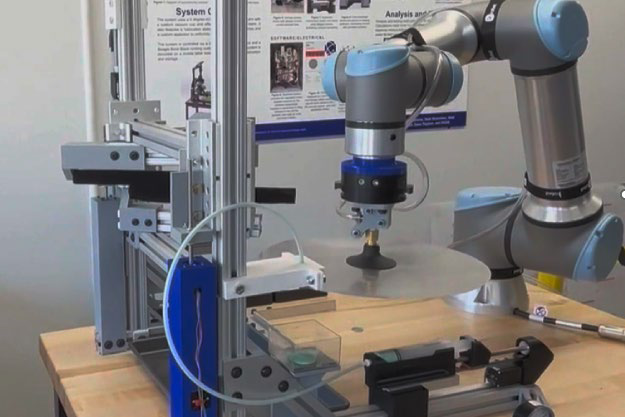
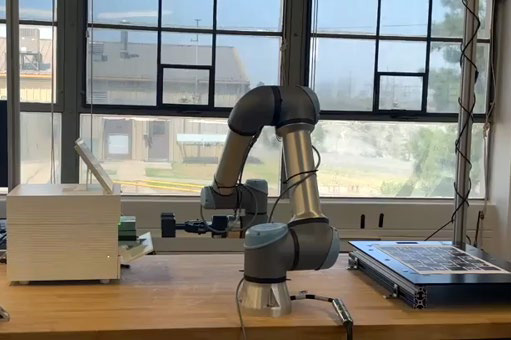
A mechanical arm on a desk with some other equiptment

This project developed a robotic proof of concept for automatically loading and unloading PCR cartridges in an iSeq sequencer. The system combines a UR5e robotic arm, ROS 2 controls, computer vision, and automated sequencer interaction. An Isaac Sim digital twin supports reinforcement learning for handling varying cartridge positions, while force limits and motion boundaries help protect the equipment during transfers.

Sponsor and Collaborator: Directed Stockpile Work Program Integration Office and BIO-GEN 

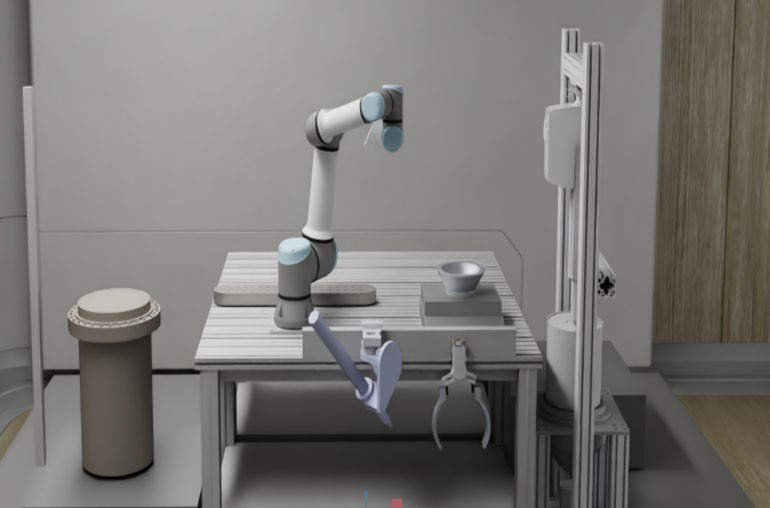
A mechanical arm on a small tabletop with some other equiptment.

This project developed a digital twin of a robotic glovebox system, to support remote monitoring and reduce the need for direct observation during verification and validation. Built in Isaac Sim, the prototype integrates computer vision, ROS 2 communication, and sensor data to track physical system activity and monitor system health. An operator interface and virtual reality capabilities support remote observation, while the simulation provides a foundation for predictive maintenance and testing responses to unusual operating conditions.

Sponsor and Collaborator: Directed Stockpile Work Program Integration Office and E-3 

A mechanical device with additional instruments and adjusters

This project focused on developing a robotic system to pick up a blank, apply lubricant to both sides, and stage it for hydroforming. The system is intended to improve lubrication repeatability, reduce manufacturing defects, and help control process variation while evaluating different materials and techniques.

Sponsor and Collaborator: Engineering Technology Maturation and SIGMA-1 

Publications 

  • Nathan Seefeld, Crystal Scott, Hyunseo (Lucia) Lee, Meredith Osborne, Nathan McLeish, Jessica Mendez, Matthew Hammond, and Beth Boardman “Autonomous Robotic Cleaning System for Selective Laser Sintering 3D Printed Parts” ASME International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Houston, TX (2026).
  • Rory Stone, Serena Lynas, Nikesh Walling, Richard Kovalcik, Aneesh Pawar, Ryan Wiersma, Jessica Mendez, Matthew Hammond, and Beth Boardman “Robotic System for Acoustic Mixing of Polymer-Bound Explosives” ASME International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Houston, TX (2026).
  • Beth Boardman, Jessica Mendez, and Matthew Hammond “Developing a Talented Workforce through the Robotics & Automation Summer School Student Pipeline” Waste Management Symposia, Phoenix, AZ (2025). 
  • Aravind Ramaswami, Colin Fricke, Aakriti Acharya, Matthew Hammond, Bryan Carlton, and Beth Boardman “Robot Arm Teleoperation for Improved Glovebox Operations” Waste Management Symposia, Phoenix, AZ (2025).
  • Olyvia Hanken-Arlen, Grayson Martin, Anunth Ramaswami, Jessica Mendez, Colin Sanders, Matthew Hammond, and Beth Boardman “A Mobile, Autonomous Bolting and Unbolting System for DOE Shipping Containers” Waste Management Symposia, Phoenix, AZ (2025).
    Award - Superior Level Rating 
  • Julia Hansen, Charlie Killian, Joseph Krahn, Nathan McLeish, Aneesh Pawar, Matthew Hammond, Beth Boardman “Laser Foil Welding on Curved and Planer Surfaces using a Robotic Arm” Waste Management Symposia, Phoenix, AZ (2025).
    Award – Papers of Note, Superior Level Rating 
  • Ritvik Dutta, Angelika Canete, William Escobar, Jackson McFall, Gregory Ford, Matthew Hammond, Beth Boardman “Precision Conveyor System for Hazardous Waste Handling” Waste Management Symposia, Phoenix, AZ (2025).
  • Desiree Dominguez, Meredith Osborne, Malacki Ehlers, Matthew Hammond, Luke Moy, Beth Boardman “Material Tracking for an Automated Canister Tracking and Storage System” Waste Management Symposia, Phoenix, AZ (2024).  
  • Richard Kovalcik, Aaron Torgesen, Chantal Morales, Gregory Ford, Nathan McLeish, Matthew Hammond, Beth Boardman “Automated Hazardous Material Transport and Storage” Waste Management Symposia, Phoenix, AZ (2024). Award - Superior Level Rating 
  • Natalie Nguyen, Matthew Coleman, Jason Pieck, Javier Ruiz, Robert Schloen, Matthew Hammond, Beth Boardman “Automated Cannister Tracking System Robotics” Waste Management Symposia, Phoenix, AZ (2024).  
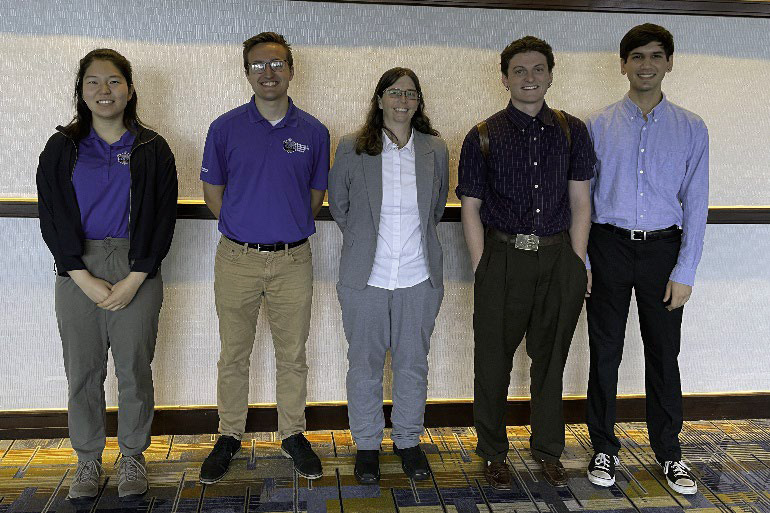
2026 RASS Cohort
RASS at ASME IDETC-CIE 2026
2025 Cohort
At the Waste Management Symposium, March 2025
2023 Cohort
At the Waste Management Symposium, March 2024

Los Alamos National Laboratory

P.O. Box 1663

Los Alamos, NM 87545

(505) 667-5061

At The Lab

  • Business Opportunities
  • Jobs
  • Organizations
  • Research Library
  • User Facilities

Information

  • Emergency
  • Ombuds
  • Reading Room
  • Resources
  • Science Museum

For Employees

  • AskIT
  • LANLInside
  • MyMail
  • Training
DOE White Seal
  • Terms of Use/Privacy

Managed by Triad National Security, LLC for the U.S. Dept. of Energy’s NNSA

Copyright 2026 Triad National Security, LLC. All Rights Reserved.

Learn about the Department of Energy’s Vulnerability Disclosure Program